Role & system
I joined the chassis and gimbal integration subteam in Fall 2025. My main design task was the holder for the M3508 motor that drives the gimbal. The holder connects the motor to the robot structure, so its bearing-block fit, fastener access, wire passage, and belt alignment all mattered to the assembly. In Spring 2026, I combined the holder with the belt tensioning interface and continued hands-on assembly and fit checks.
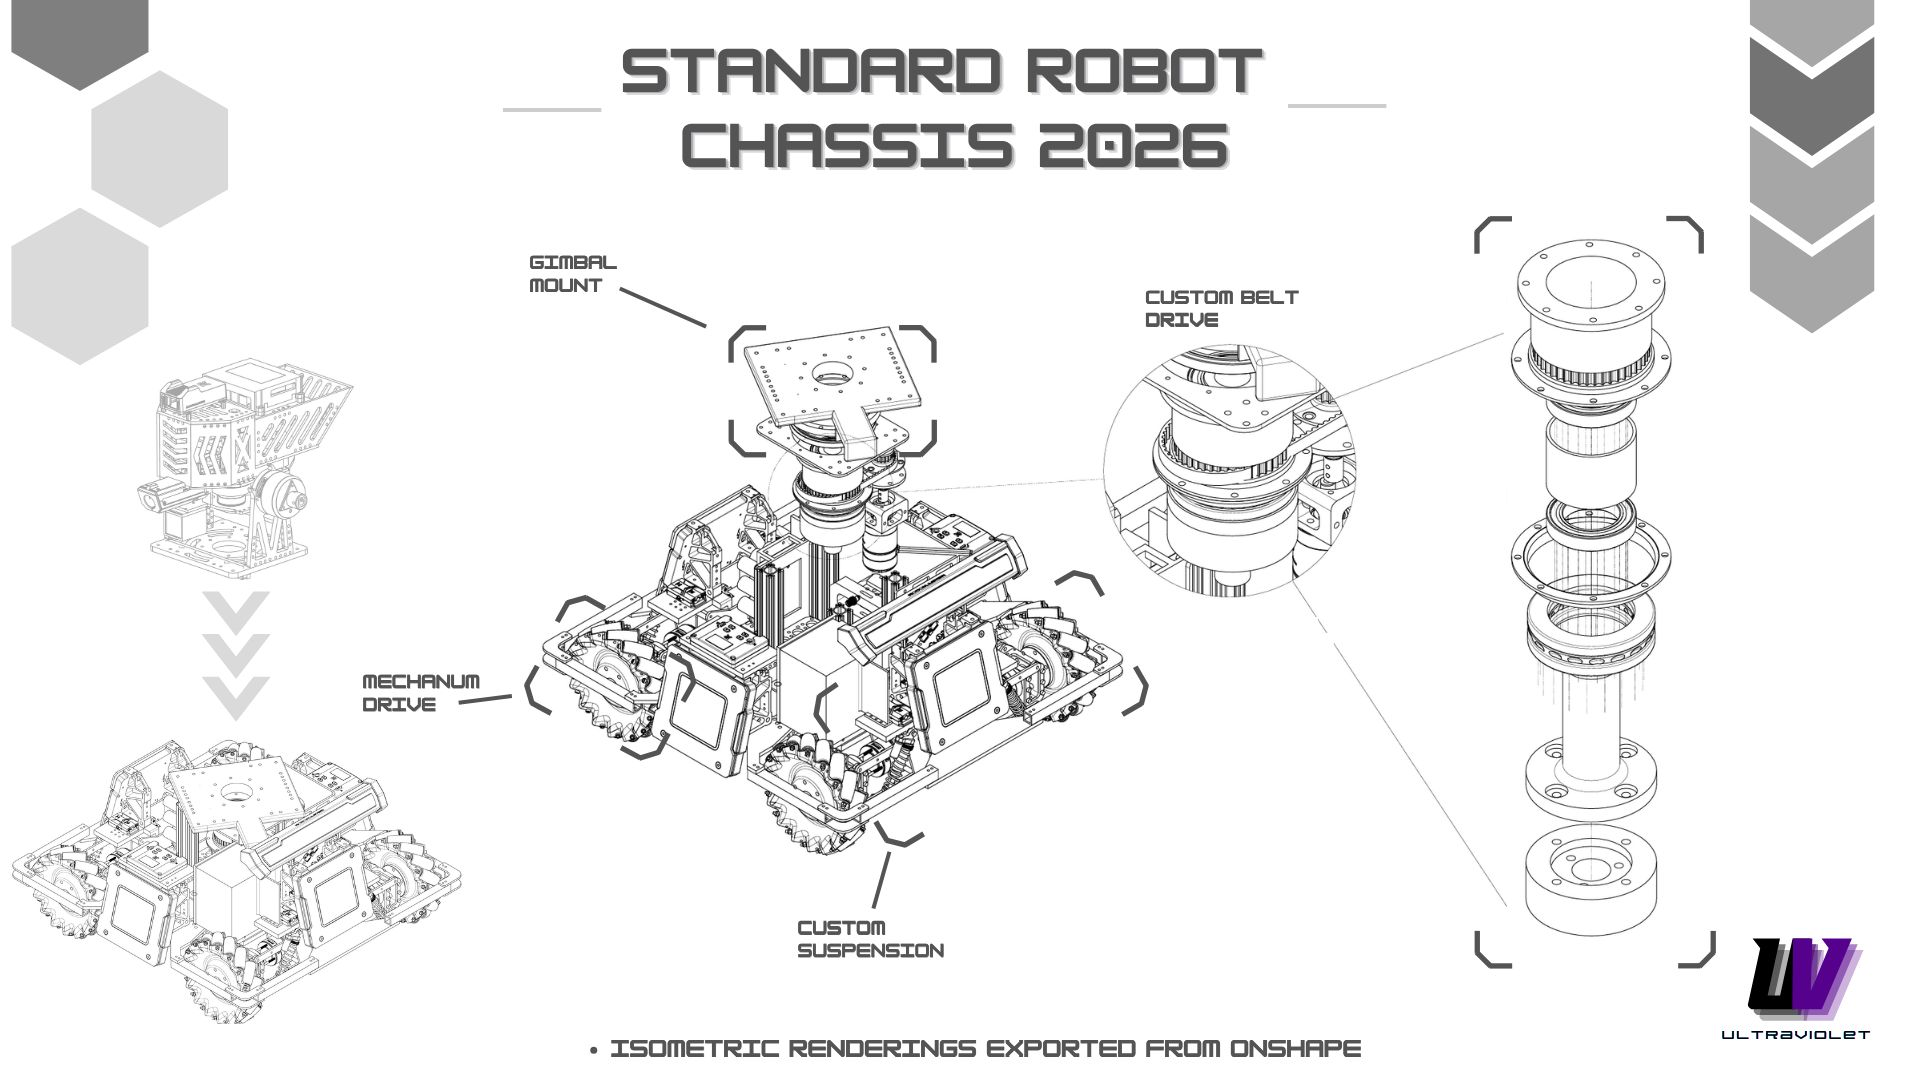
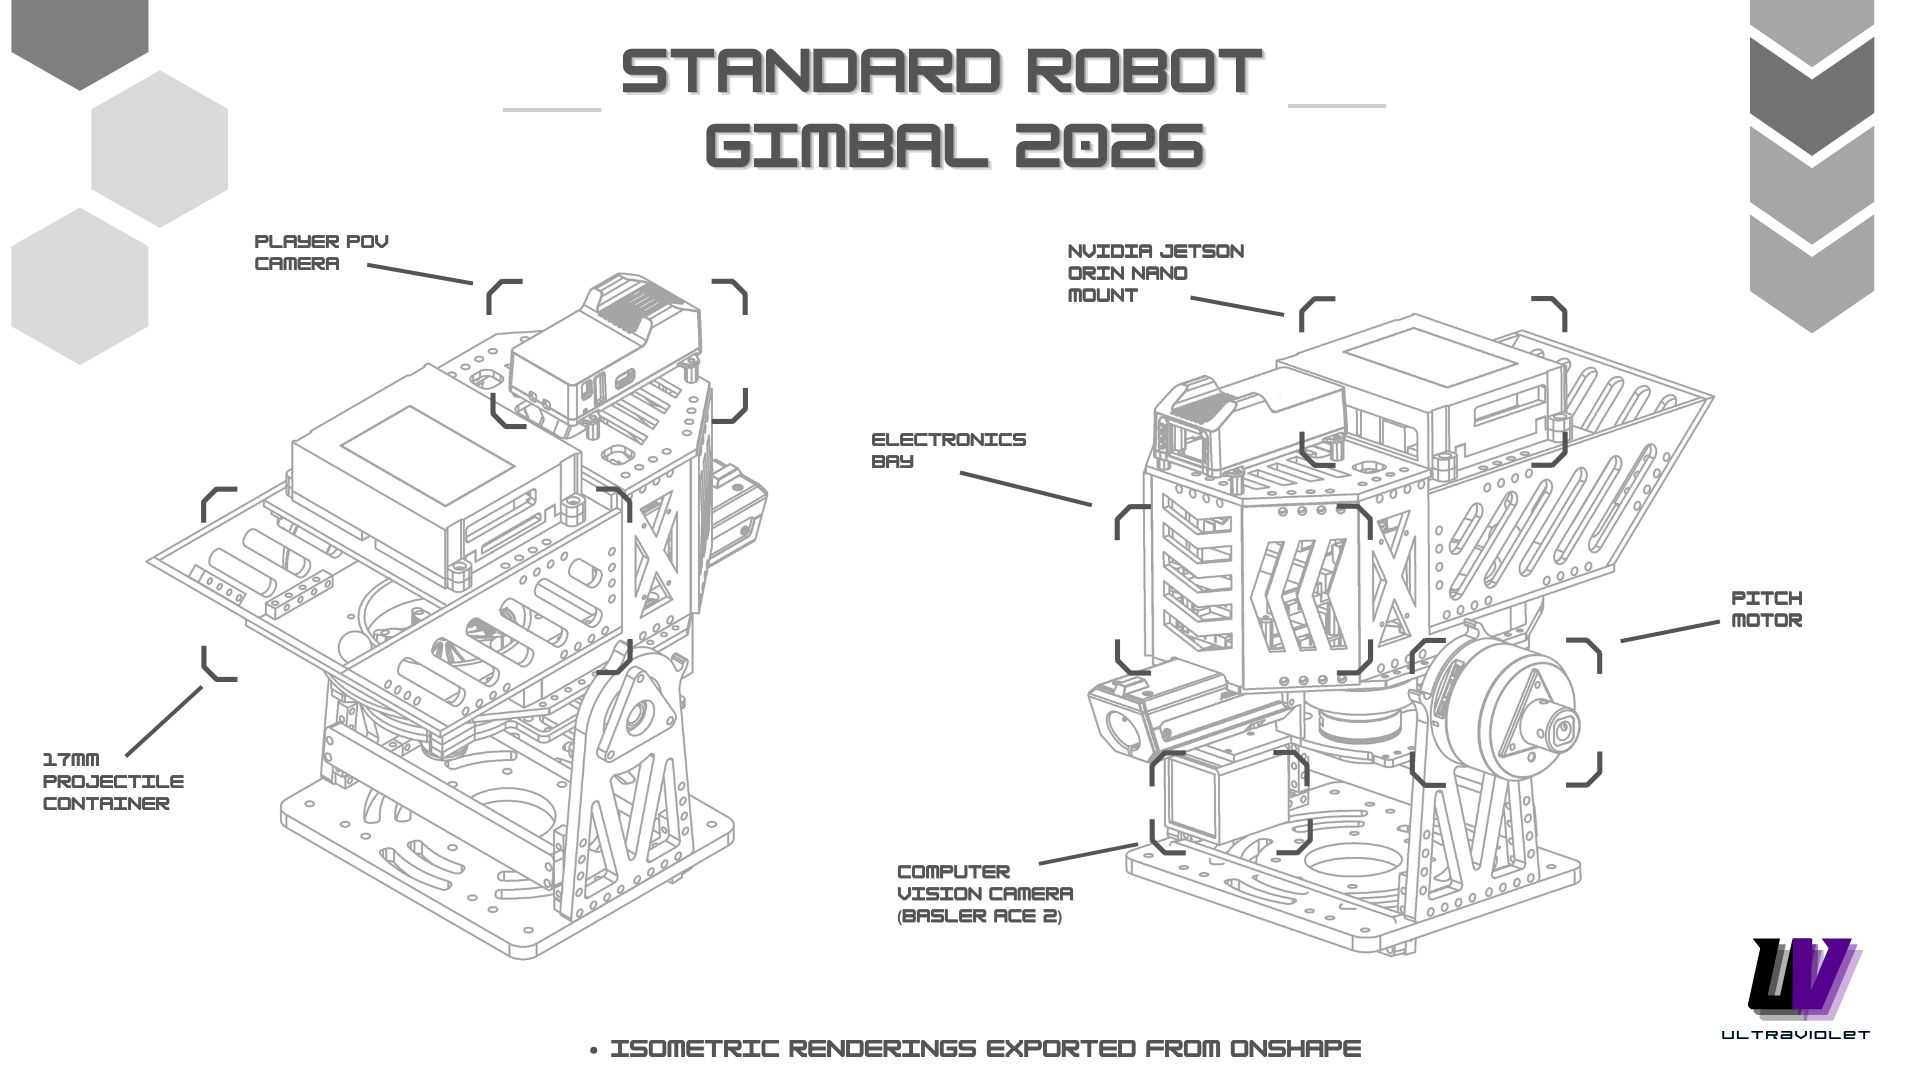
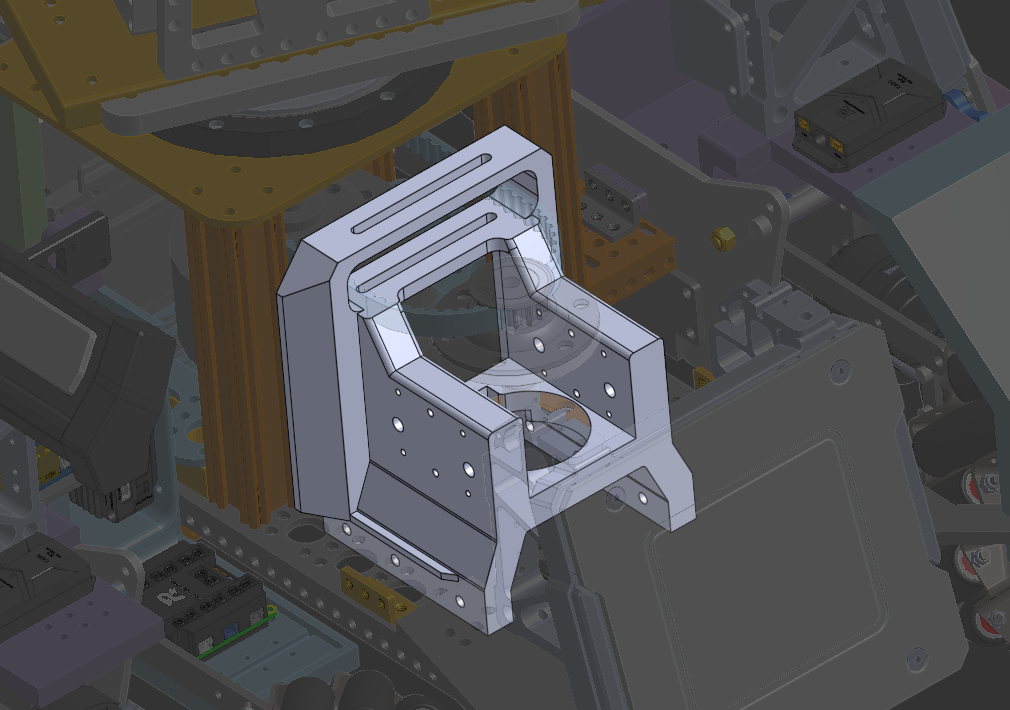
My work covered the motor mount, its integration details, printed fit-check prototypes, and fabrication and assembly support. The team system drawing below shows where the gimbal and mount fit within the standard robot.
Motor mount iterations
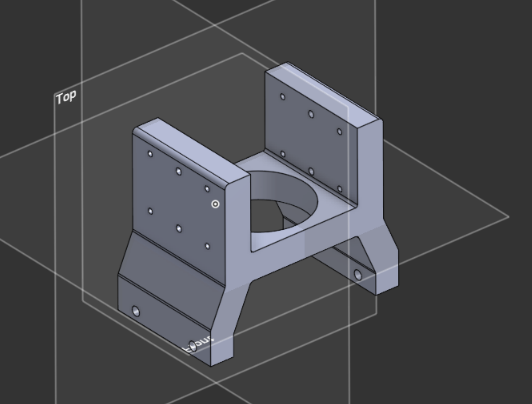
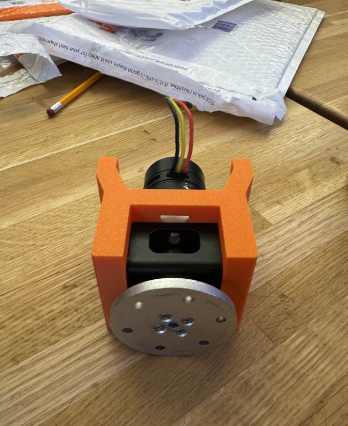
I first fitted the M3508 around the existing bearing block, then increased material around the holder for strength. When the bearing block changed, I revised the geometry to accept the new block, leave a path for motor wiring, and retain practical fastener access. Printed prototypes let us check the motor and bearing fit before carrying the design into the assembly.
- Initial fitMotor holder around the old bearing block.
- ReinforcementThicker holder geometry for the mounting interface.
- Revised blockUpdated bearing-block fit and wire clearance.
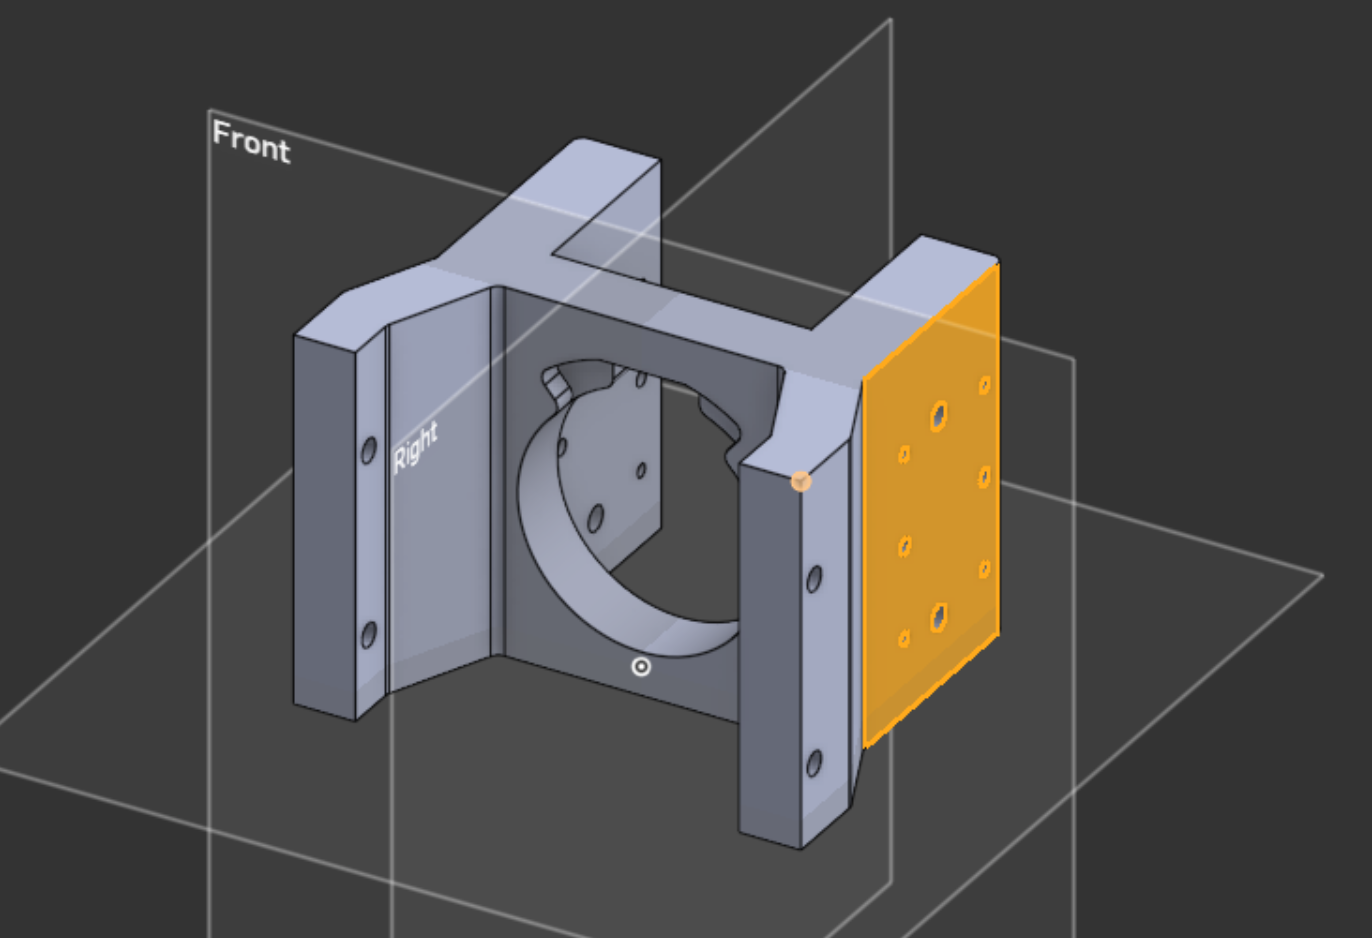
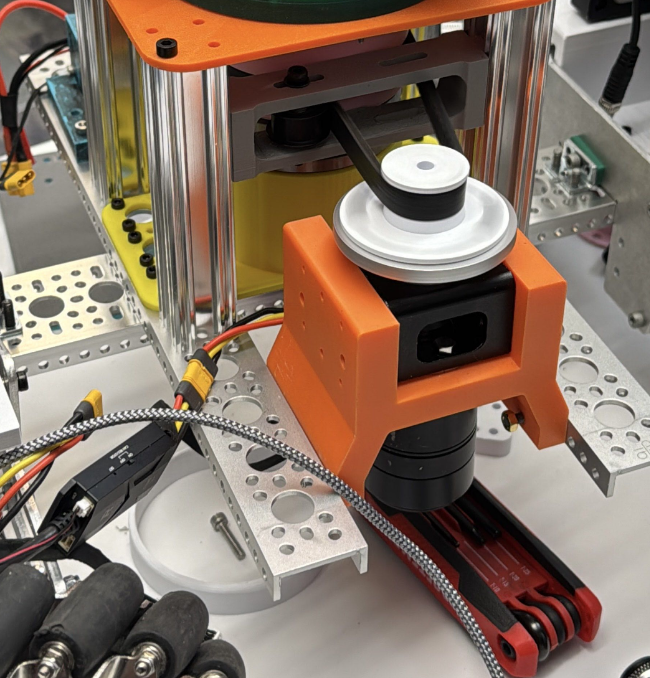
- IntegrationMotor holder joined to the belt tensioning mount.
Belt tensioning interface
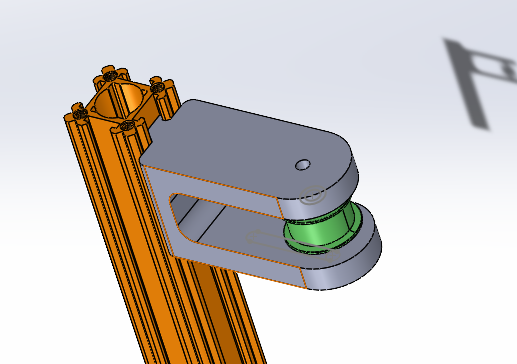
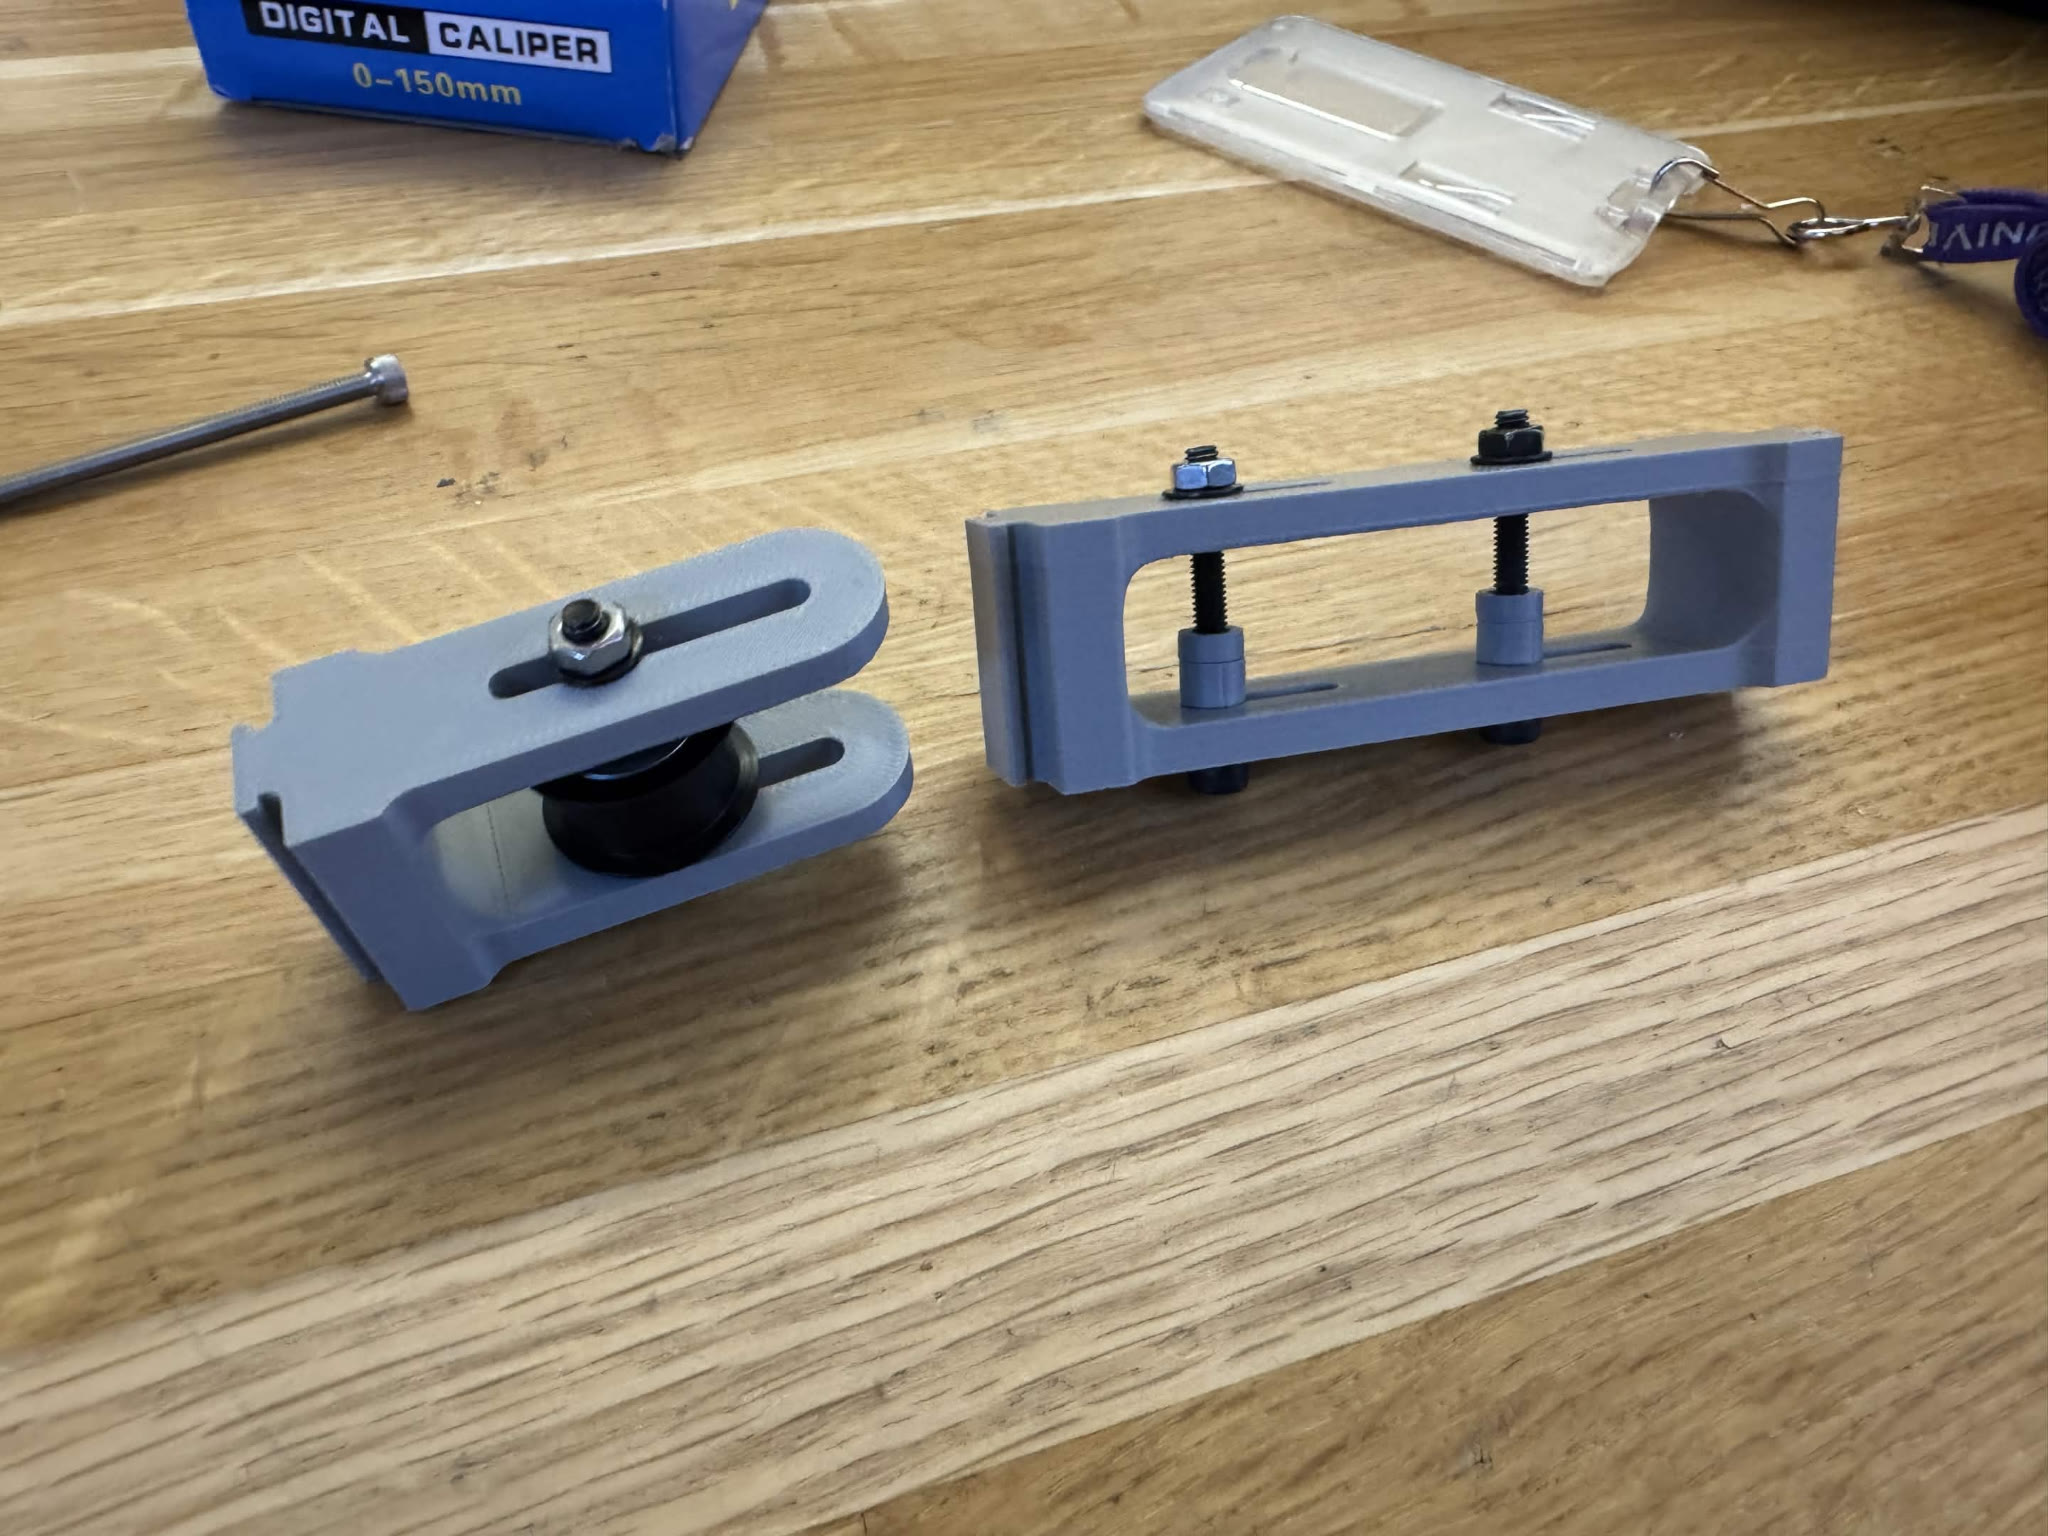
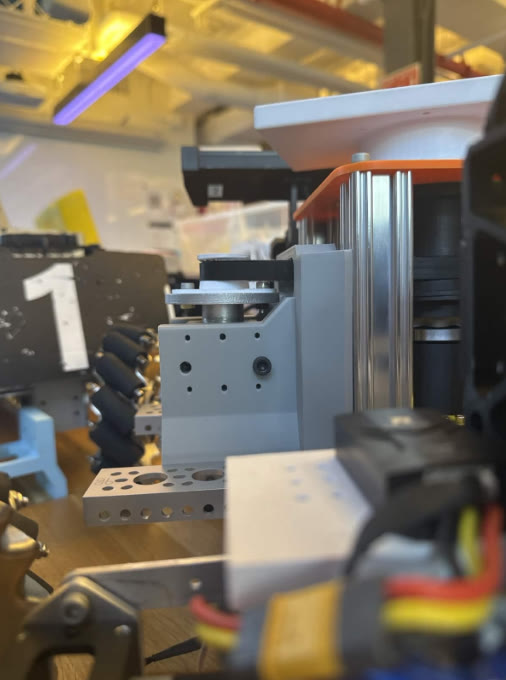
For the gimbal belt drive, I designed and printed a tensioner prototype, then explored single- and dual-bearing versions. I later redesigned the motor holder and tensioner as one unit, adjusting its mounting points and height to match the belt path in the physical build. The short clip below shows the combined setup working during a tensioning check.
Assembly & fabrication
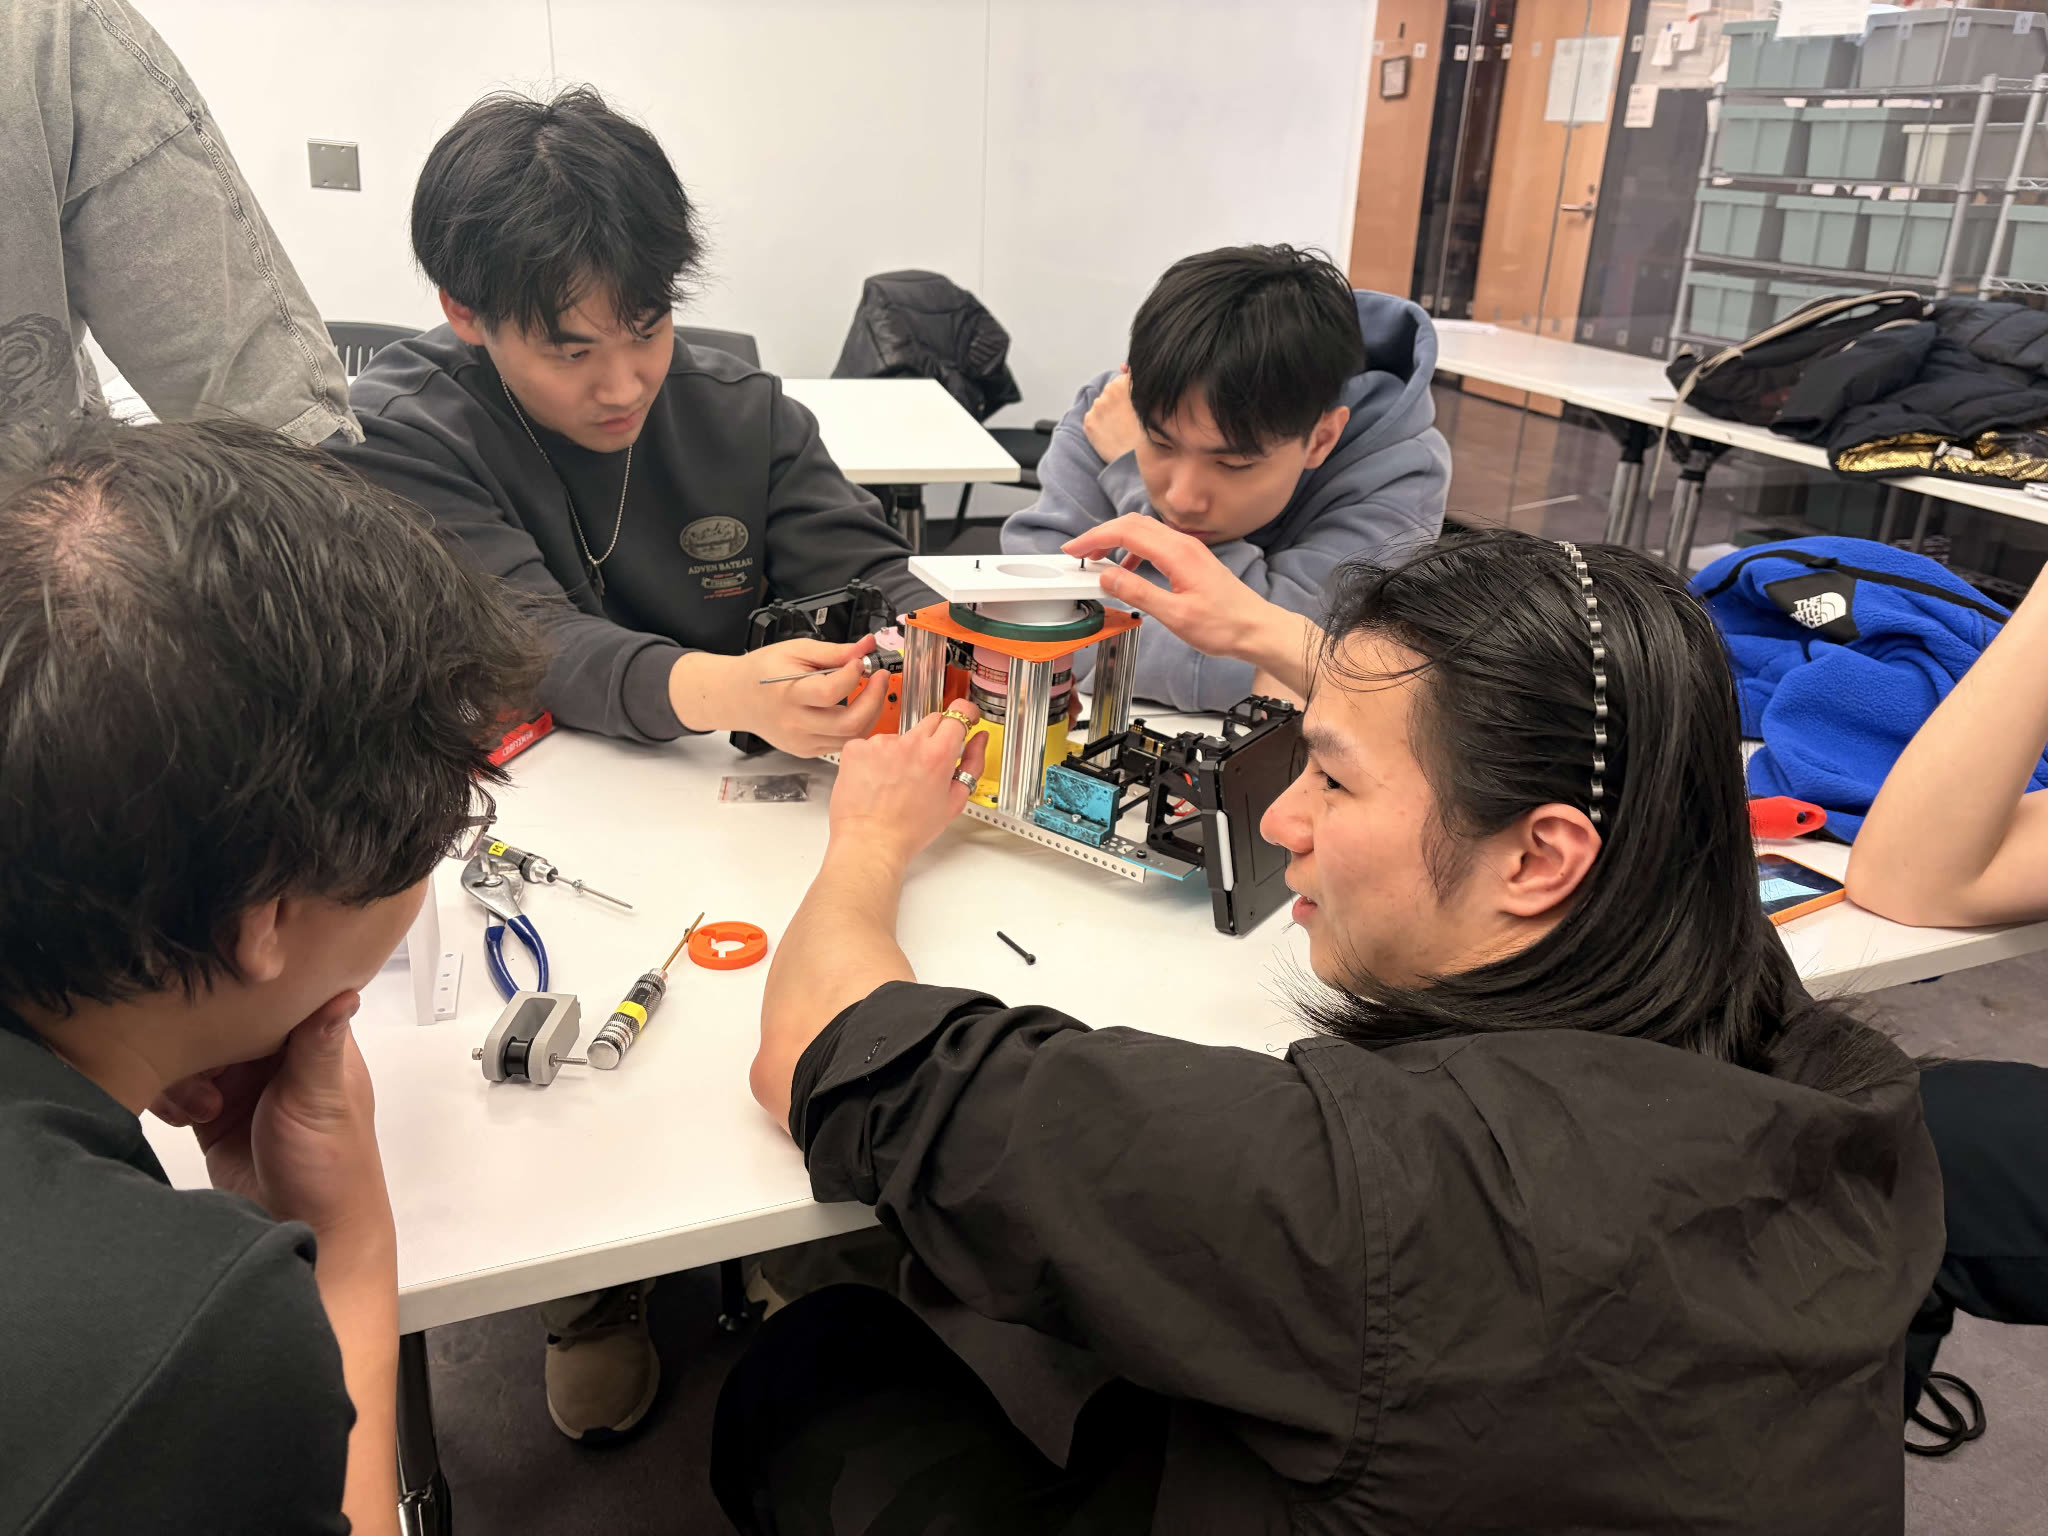
Alongside the mount design, I coordinated prototype printing and tracked revisions and print-queue status in Excel. I worked with teammates to assemble the standard robot, check component spacing and the belt path, and resolve physical fit issues as parts came together.
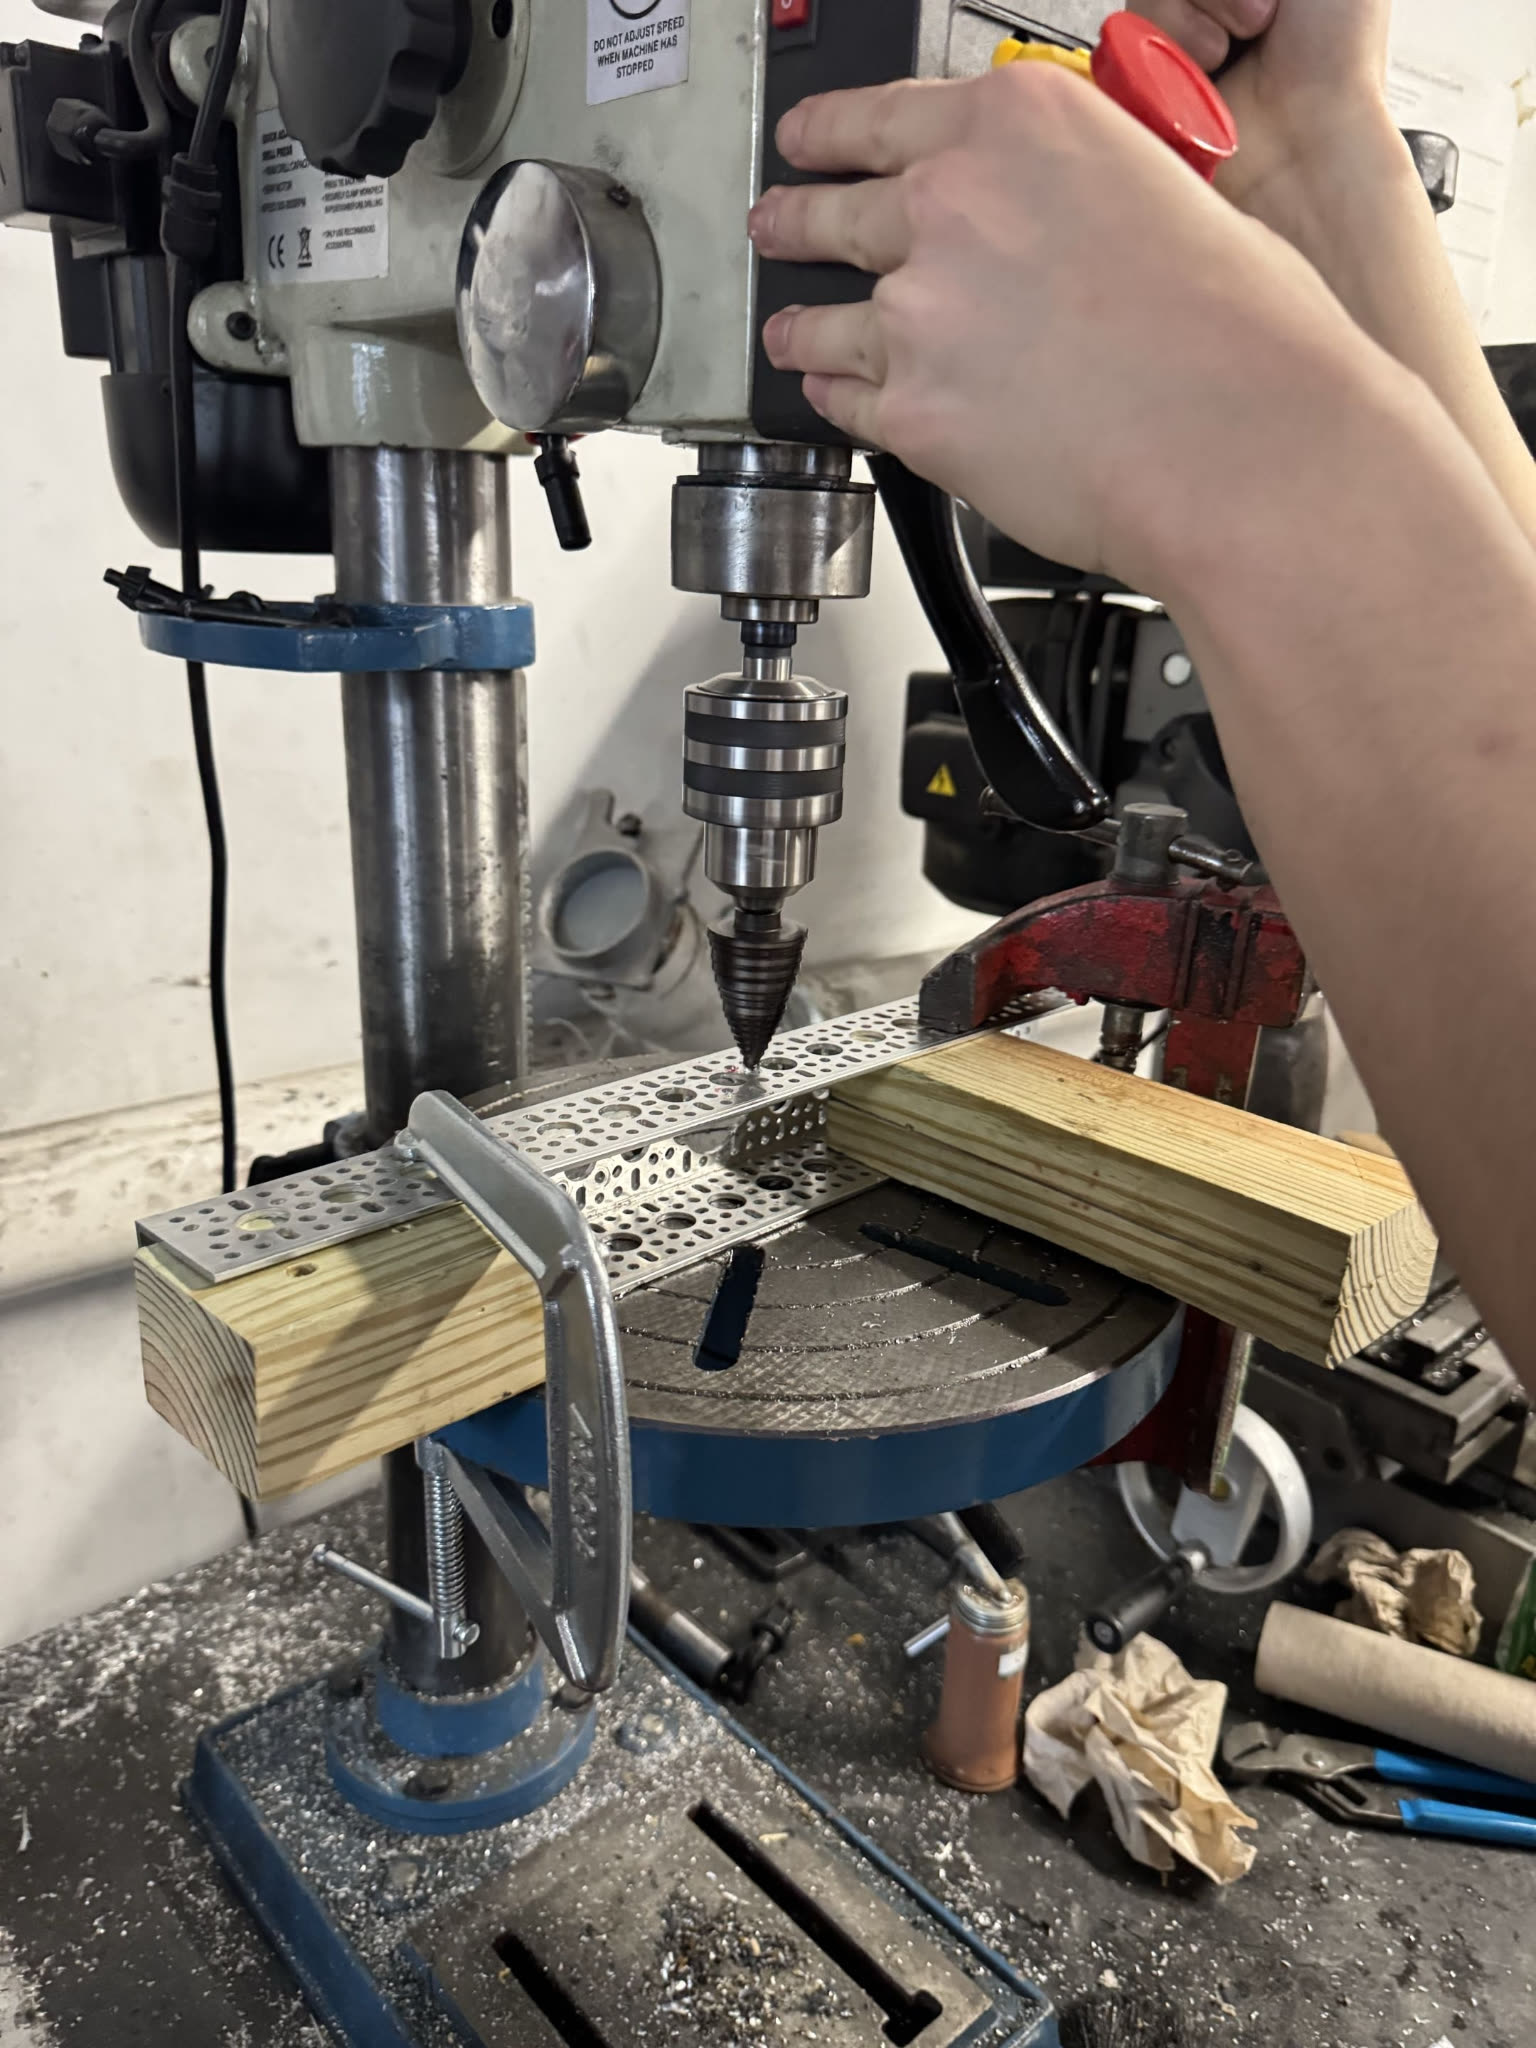
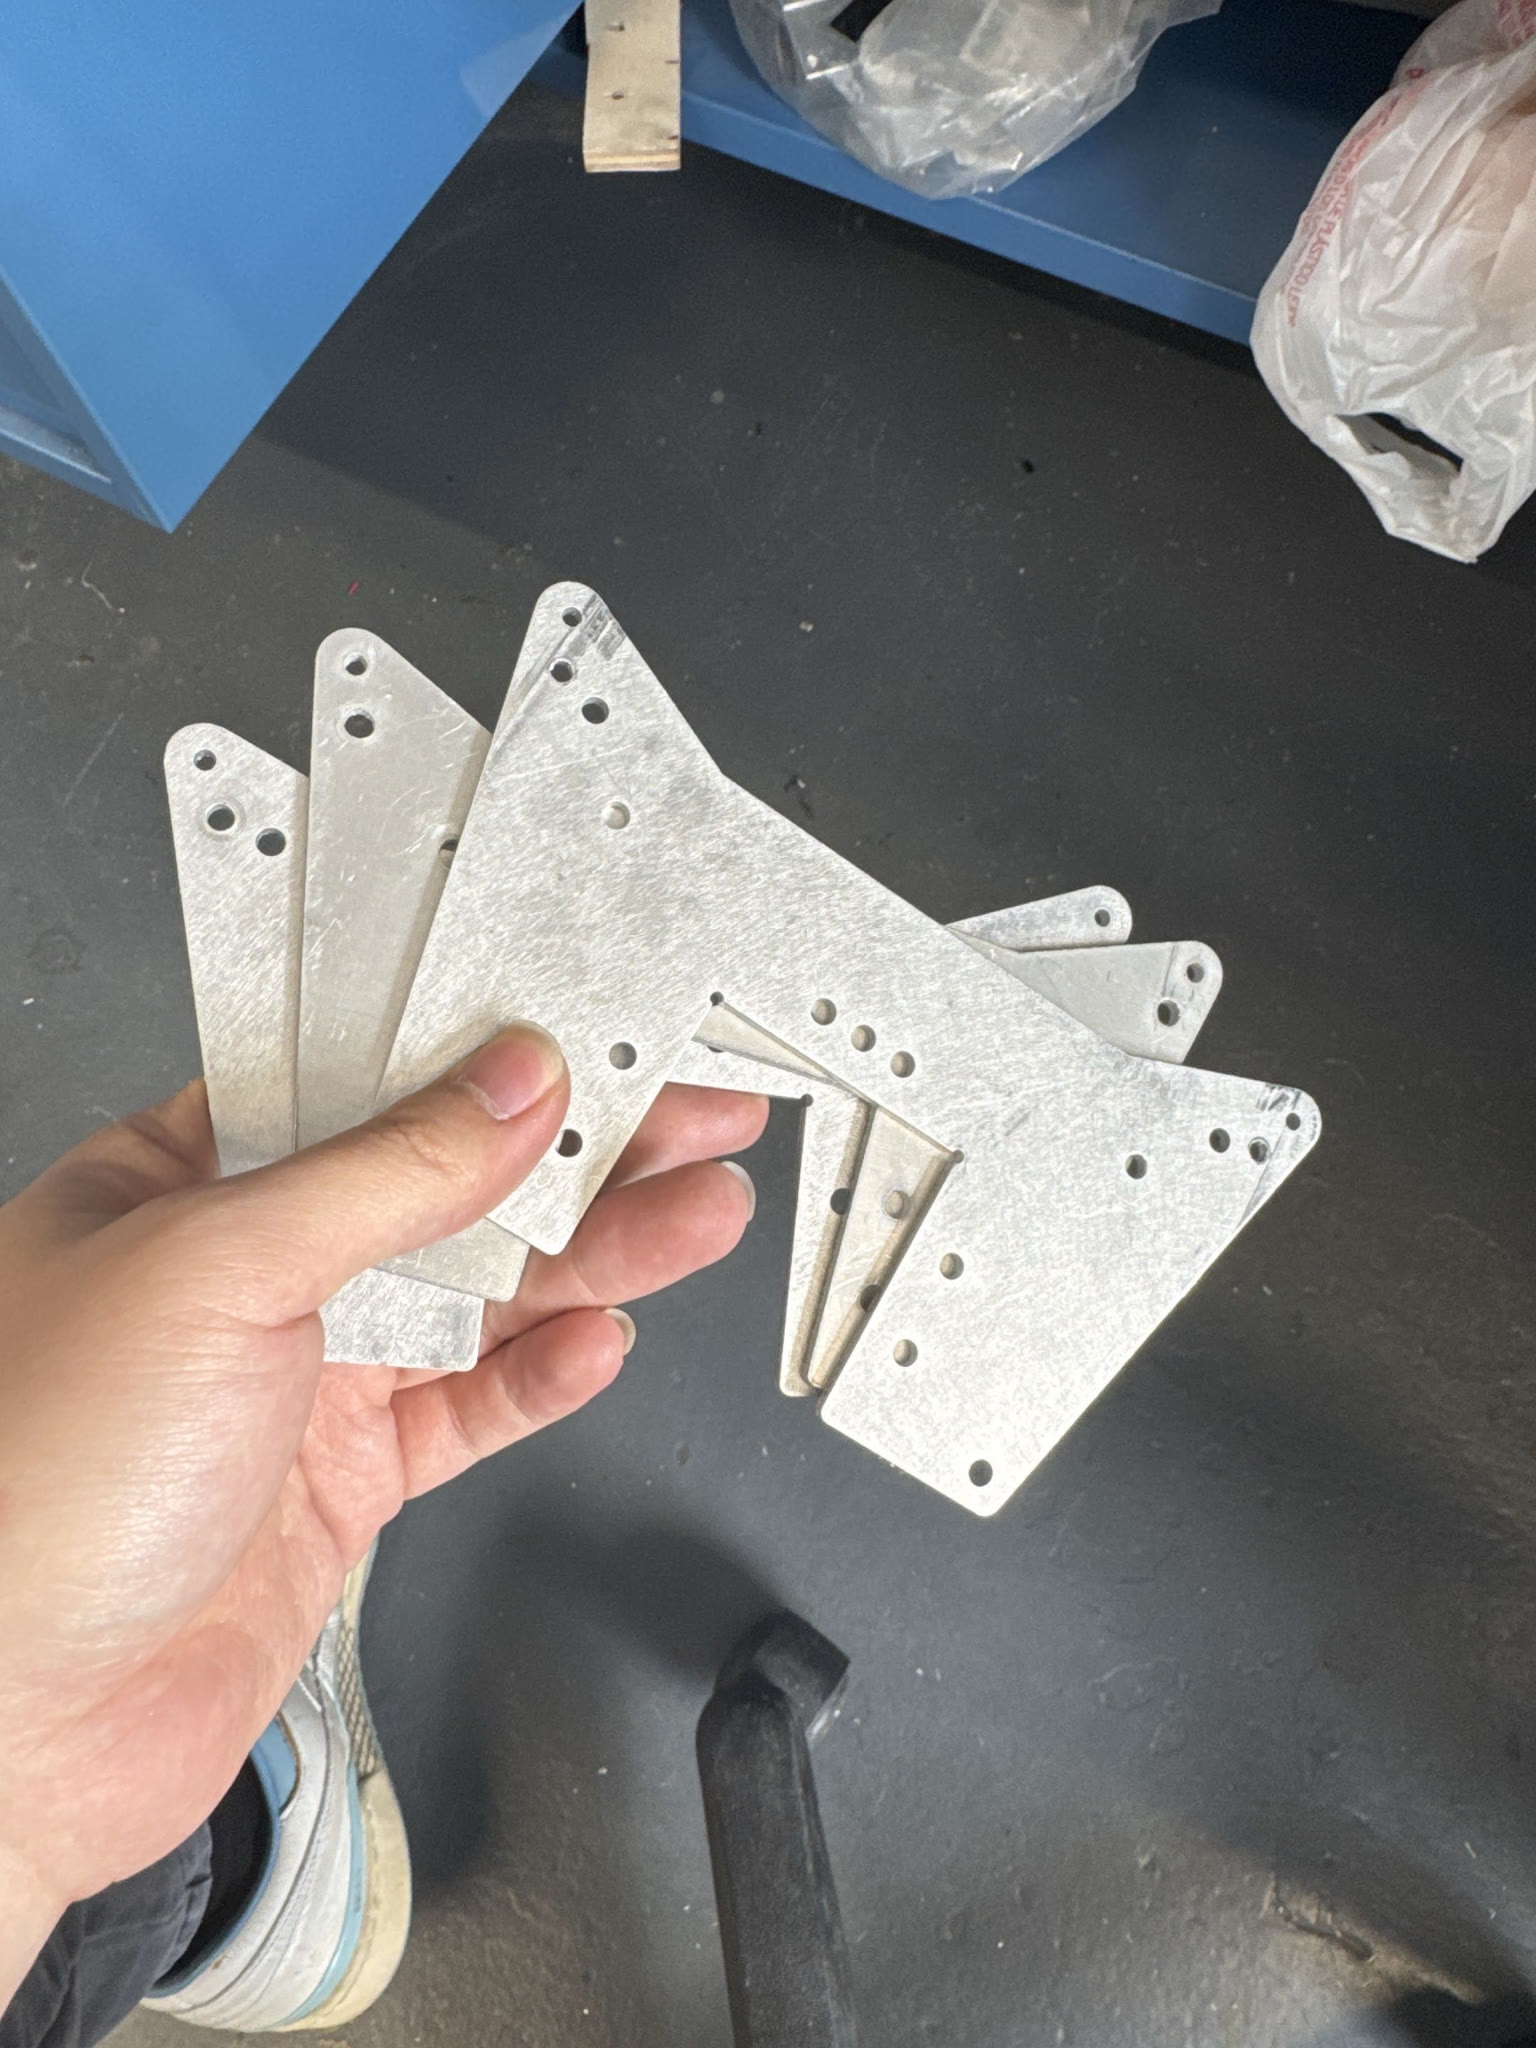
I drilled the slip-ring opening through the chassis spine using a drill press, including the larger replacement spine, and corrected mounting holes in metal plates when the manufactured pattern did not line up during assembly.
System demos
These team demos show the finished standard robot’s gimbal and chassis in motion, with the motor mount and belt tensioner installed as part of the full assembly.
Team outcomes
At the ARC Robotics competition, the team won a 1v1 match against Austin Community College and a 3v3 match against UC San Diego. The team delivered three presentations, received two Outstanding Presentation awards, and placed 11th among 21 teams overall. These are team results from the 2025–26 season; my contribution to the standard robot was its gimbal motor mount, belt tensioner, and integration work described above.
Watch NYU’s 3v3 win against UC San Diego (UCSD) ↗
RoboMaster UltraViolet is now ARC Robotics. This page covers my mechanical subteam work through Spring 2026.
Since Fall 2026, I have served as mechanical lead for ARC Robotics’ Engineer robot team. That project is ongoing.